 codesignprojects
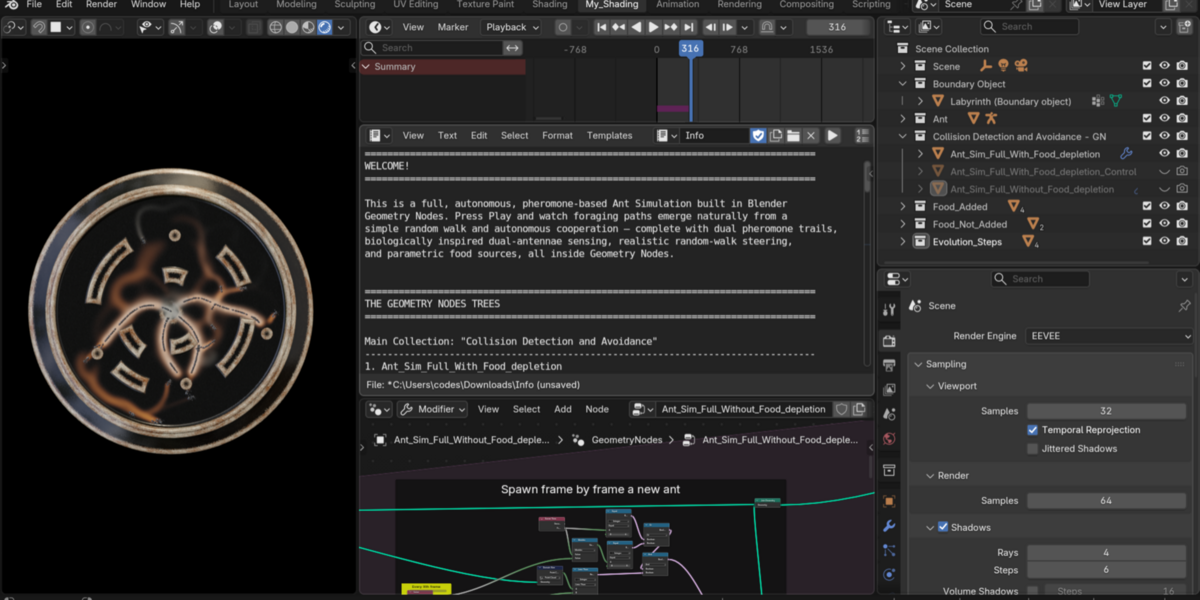
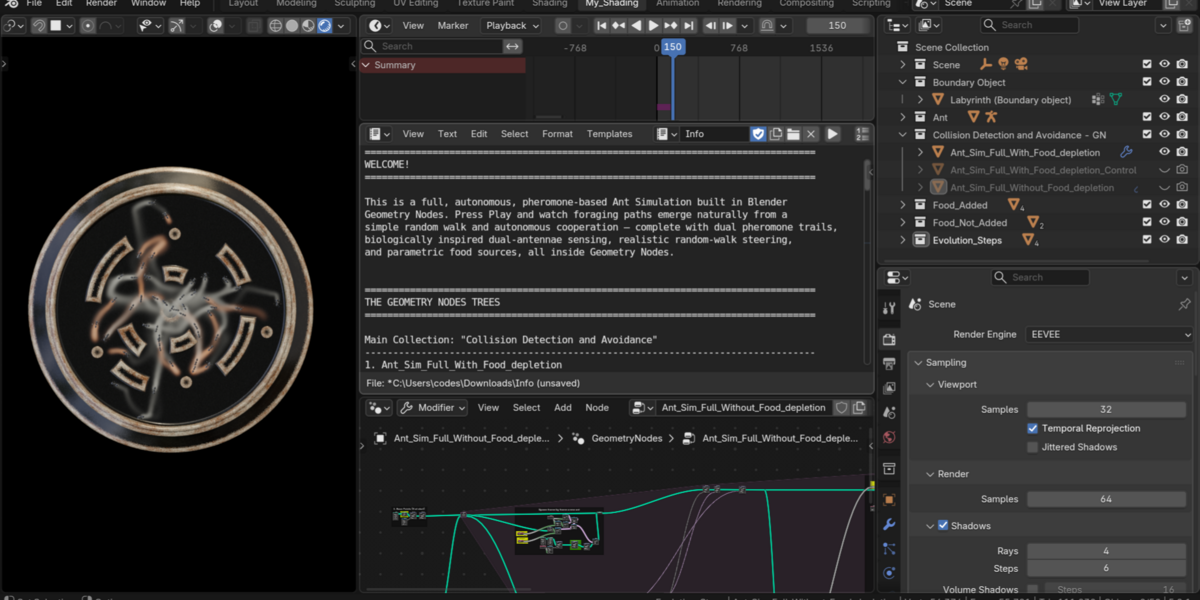
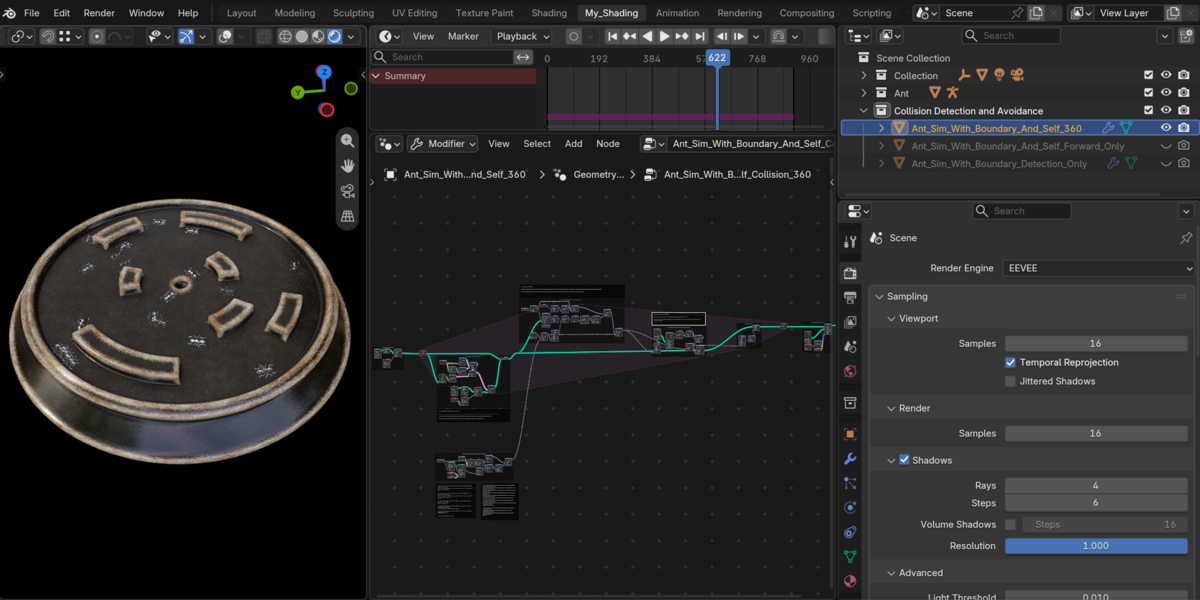
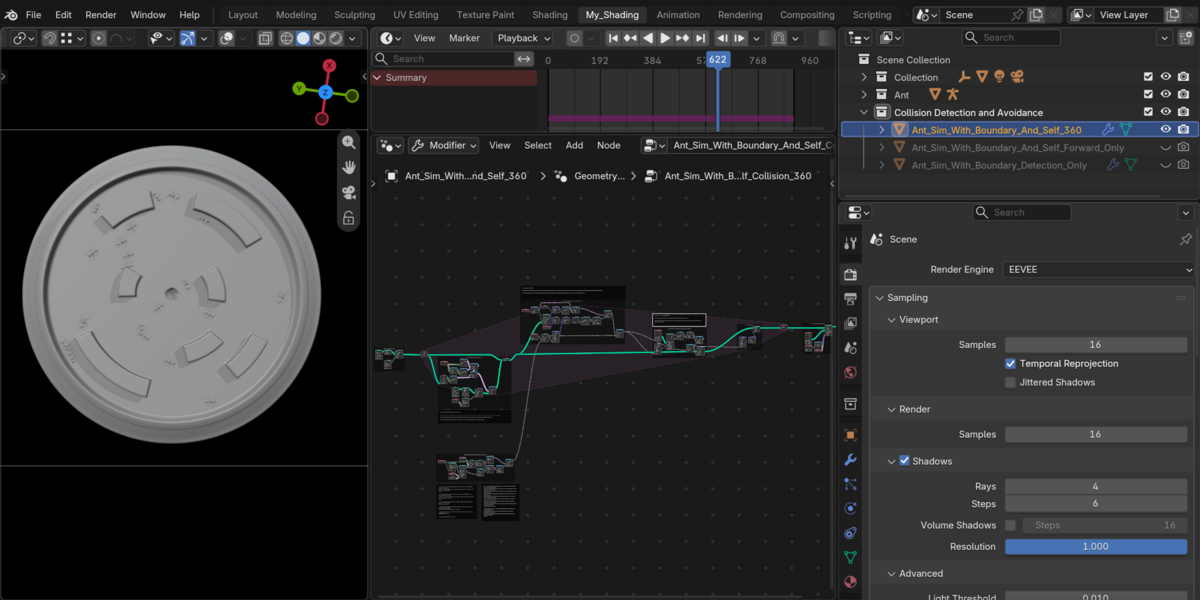
The Swarm Intelligence Suite combines two complementary, 100% native Geometry Nodes simulation setups - taking you from foundational boundary & neighbor collision avoidance up to full dual-pheromone emergent foraging.
📦 The Bundle : Both Ant Simulation and The Hive together in one organized suite at a discount!
What's Included (5 Cleanly Organized .blend Files):
1. Ant Simulation — Dual Pheromone & Emergent Foraging
- Full_Ant_Simulation_With_Pheromone.blend: Complete autonomous, pheromone-based Ant Colony Simulation built 100% in Geometry Nodes - featuring dual Blue/Red pheromone grids, dual-antennae sensing, random-walk steering, wall collision avoidance, depleting food sources, 4 progressive learning steps, and both an educational annotated tree and a 24-parameter modifier-controlled setup.
- ▶ Video demo: YouTube Demo
2. The Hive — Procedural Boundary & Self-Collision Avoidance (4 Files)
- The_Hive_Swarm_Collision_Detection_And_Avoidance.blend: Main autonomous boid swarm with both Boundary Raycast + Forward-Scan Self-Collision and Boundary Raycast + 360-Degree Neighbor Scan.
- EXAMPLE_Lines_moving_in_direction.blend: Step 1 — Baseline Simulation Zone radial point emission and movement.
- EXAMPLE_Lines_moving_with_random_Direction_Change.blend: Step 2 — Per-instance internal clocks and randomized turn probability.
- EXAMPLE_Lines_moving_with_random_Direction_Change_AND_Collision.blend: Step 3 — Obstacle collision detection combined with randomized steering.
- ▶ Video demo: YouTube Demo
Key Features:
- 100% Native Geometry Nodes — Zero third-party add-ons or Python scripts required.
- Educational & Production-Ready — Step-by-step learning scenes, color-coded node frames, and modifier-exposed controls.
- Complete Swarm Progression — Learn core raycast/neighbor steering in The Hive, then scale up to full stigmergy & pheromone trails in Ant Simulation.