 codesignprojects
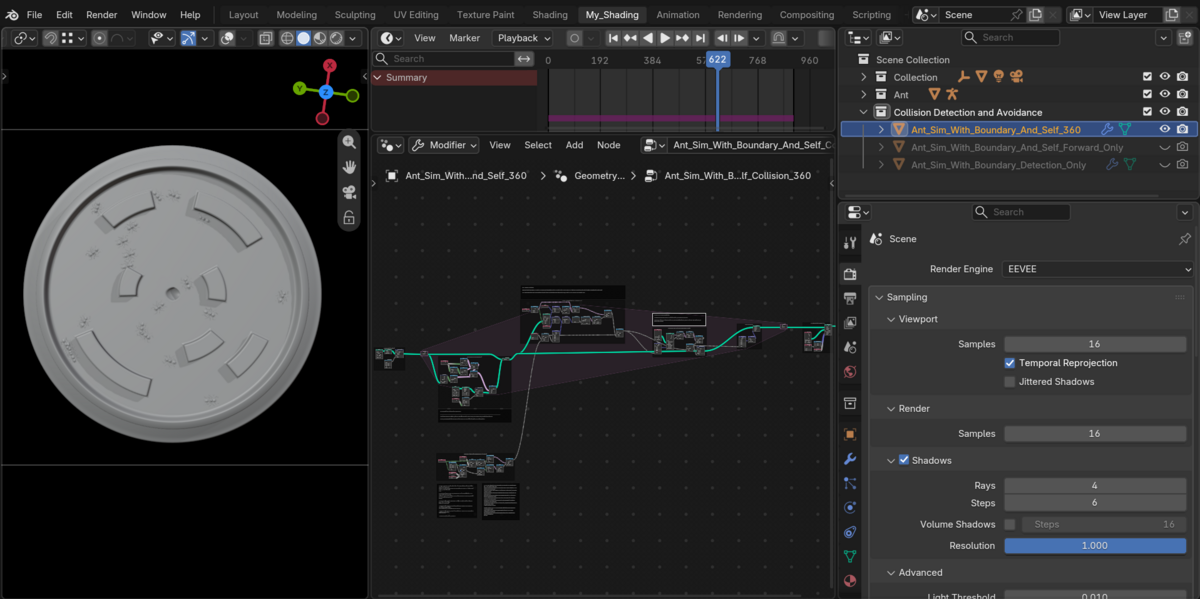
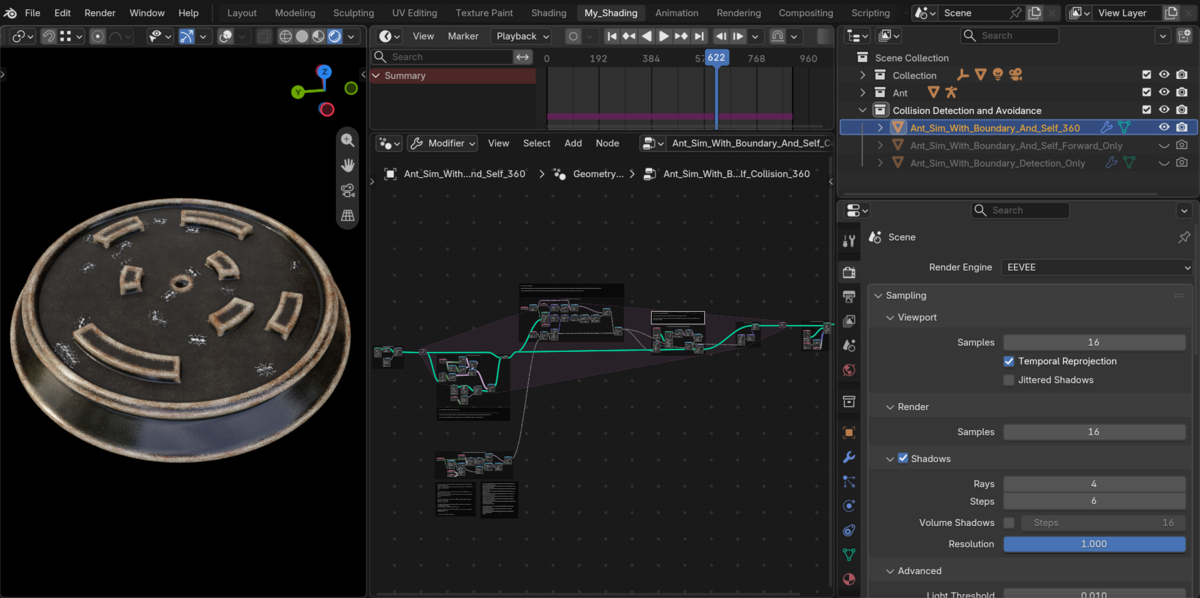
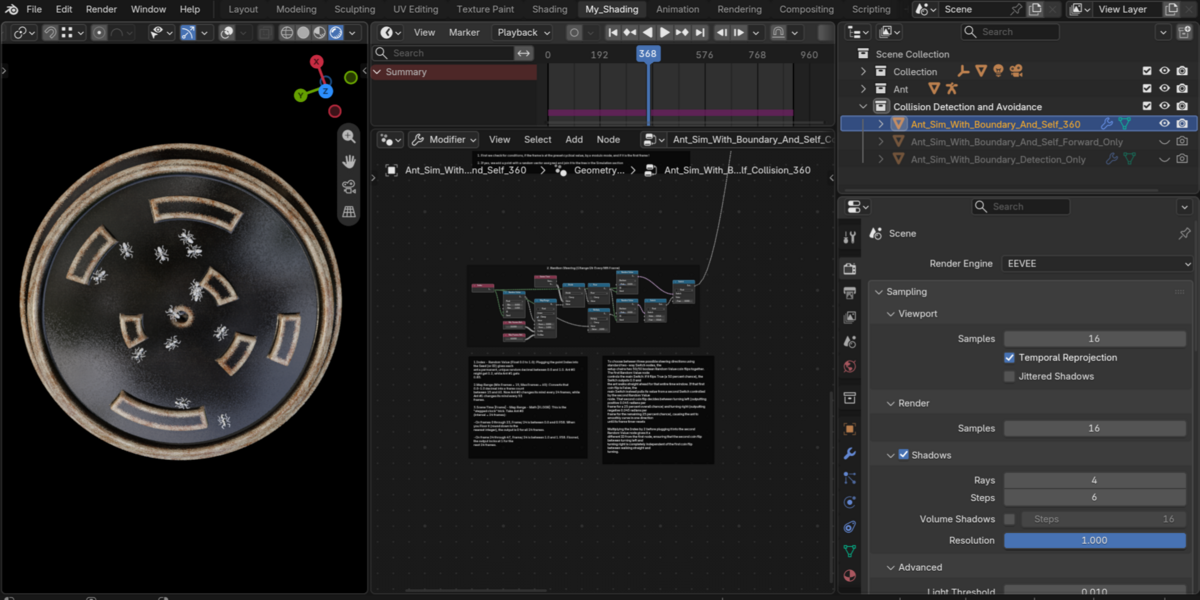
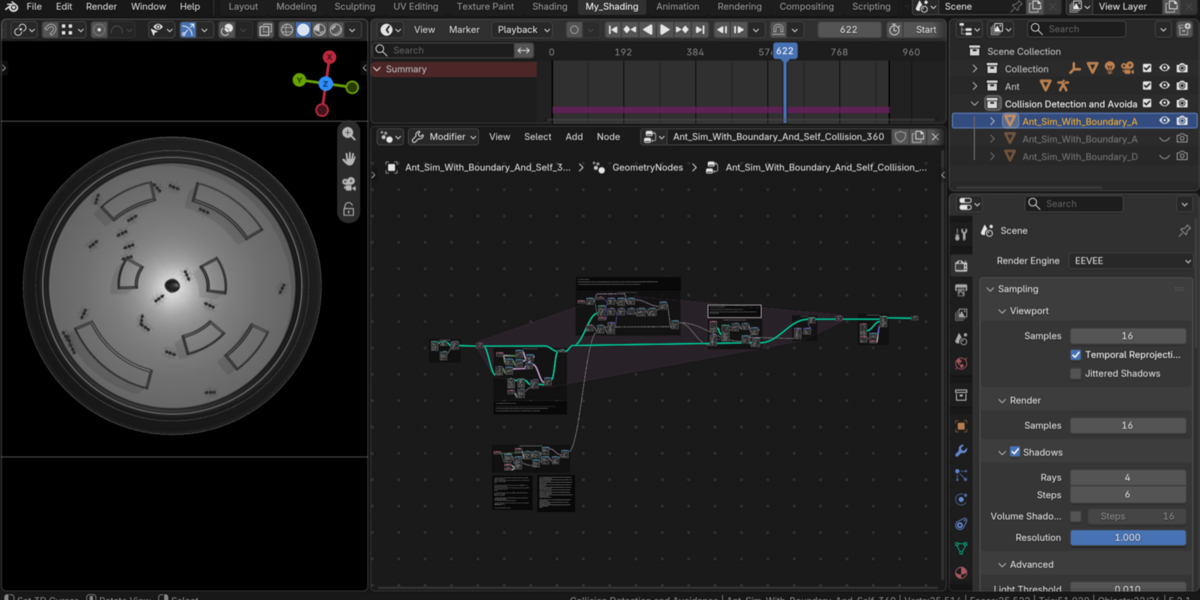
A pure Geometry Nodes implementation of boundary and self-collision avoidance in Geometry Nodes - Illustrated by an autonomous swarm. Steering, obstacle navigation, and neighbor collision detection, with multiple methods for behaviour - forward cone detection, 360 degree scan and so on.
Designed for clarity and easy of read, it breaks down procedural crowd (boid) motion into four modular steps, from the basic movement and randomization, to collision-detection. Every node tree is fully framed and labeled, giving you direct control over emission intervals, population caps, steering rhythm, agent-radius, and raycast look-ahead distances — providing a blueprint for state-driven simulation loops in Geometry Nodes.
▶ Video Demos: Demo (YouTube)
What is Included:
For exact node-level details, see the Documentation section!
(The Main file with description, and 2 additional setups):
- 1. Radial & Random Direction Movement (Separate File): Demonstrates baseline point velocity inside a Simulation Zone, moving instances outward along randomized initial headings.
- 2. Adjustable Stepped Steering & Probability (Separate File): Introduces per-instance internal clocks using floored frame division and chained boolean switches to control turn frequency, angle, and straight-vs-curve probability.
-
Main file - Boundary Raycast & Forward-Scan Self-Collision: Combines forward raycasting against labyrinth walls with a forward-hemisphere neighbor check (
Dot Product > 0) and distance threshold to trigger turns only when another instance is directly ahead. -
Main file - Boundary Raycast & 360-Degree Neighbor Scan: Evaluates full radial proximity around each instance using cross-product directional steering (
Cross(Forward, ToNeighbor).z) to veer left or right away from nearby neighbors.
Workflow Tip:
Try whichever method catches your fancy, and see the detailed labels at the node groups !
Developer's Note:
These node trees are kept open and modular for readability and feature detailed frame-by-frame explanations. Everything is built from pure math nodes from the ground up.
The goal is to provide a transparent core of the mathematical concept, node by node, rather than hiding the equations inside locked node groups. You can inspect, modify, and extend every branch to realize your own visualizations.
Support & Contact:
Blendermarket Inbox
[email protected]
See more on Instagram or YouTube
Recommended Tools:
The Wire
Kinetica
The Visitor