 Marco Sibaldi


⚠️ IMPORTANT: This product requires the PCM_Core plugin to function ⚠️
Purchase PCM_Core here.
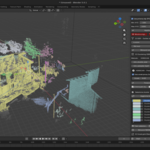
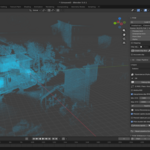
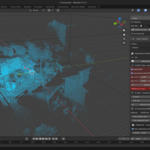
PCM_Clean is a professional point cloud cleaning and optimization addon for Blender.
Designed for architects, surveyors and LiDAR professionals, this addon provides a structured workflow to remove noise, isolate structures and simplify large point clouds while preserving geometric features.
Raw scans generated by LiDAR and SLAM devices often contain noise, redundant points and unnecessary data that make modeling difficult and slow.
PCM_Clean solves these problems through a multi-step cleaning pipeline specifically designed for architectural and surveying workflows.
The addon integrates directly inside Blender and works seamlessly with PCM_Core, enabling a complete workflow from point cloud import to optimized modeling-ready data.
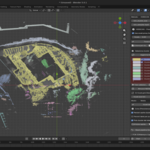
Main features include statistical noise removal, clustering algorithms to isolate structures and voxel simplification to reduce point density while maintaining the original geometry.
Typical workflow:
1. Import the point cloud using PCM_Core
2. Select the region of interest
3. Remove noise using statistical filtering
4. Isolate structures using clustering
5. Simplify the point cloud with voxel reduction
6. Continue modeling or export the cleaned data
PCM_Clean is part of the PCM – Point Cloud Modeling suite for Blender.
The goal of the suite is to bring professional point cloud processing tools directly inside Blender, enabling efficient workflows for architecture, BIM modeling and digital surveying.
Recommended workflow:
• PCM_Core – Point cloud import and visualization
• PCM_Clean – Point cloud cleaning and optimization
• PCM_CAD_Extract – CAD extraction tools (coming soon)